Platform
Airframe & companion computer
Keep the aircraft under 25 kg — above that is Transport Canada’s medium-drone class and a different regulatory project. Software gaps are closed; remaining work is blocked on hardware that does not exist yet.
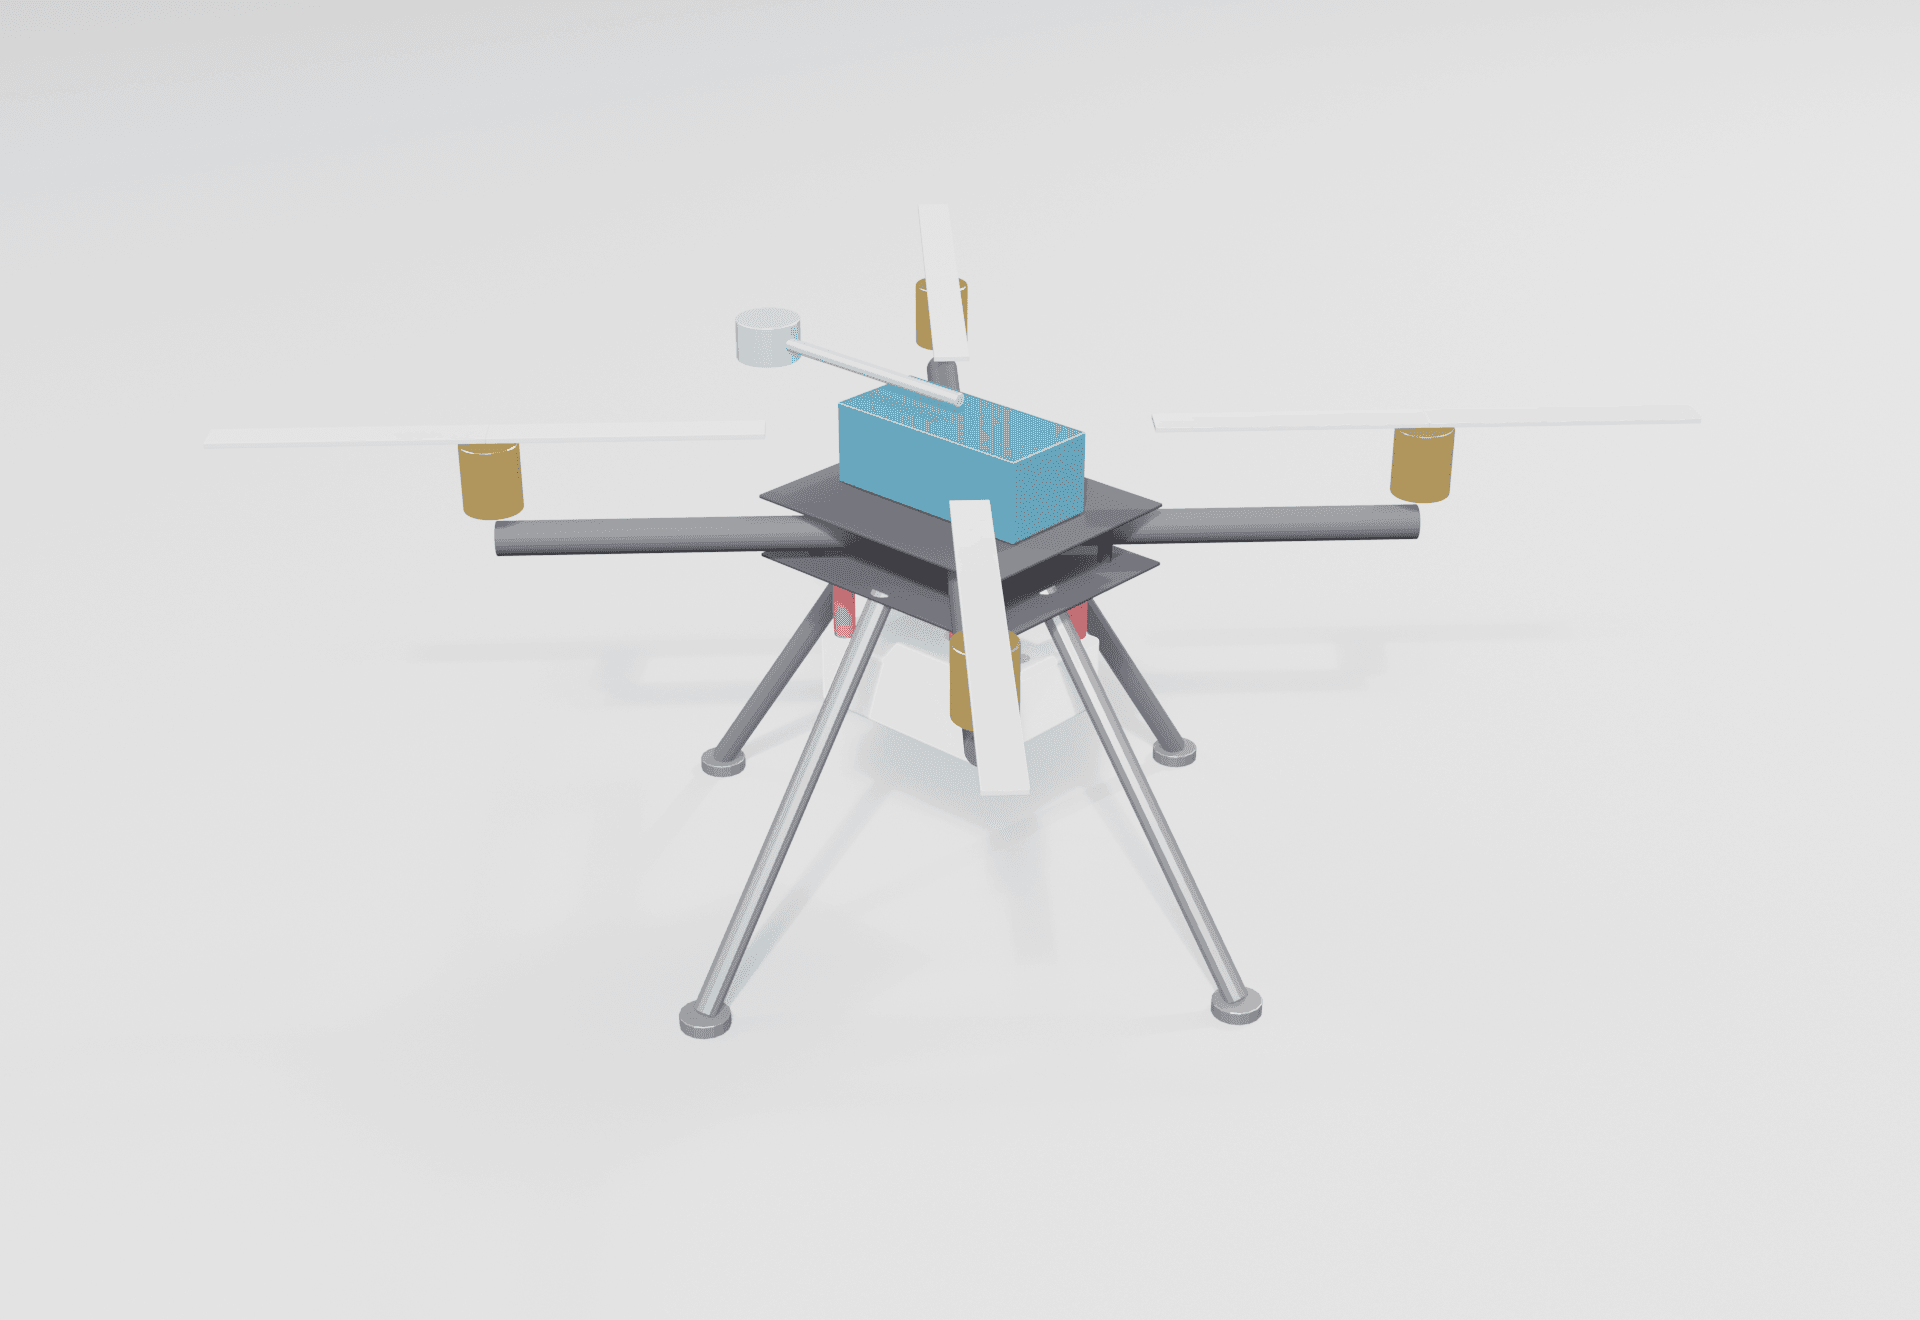
Three views of the airframe
Product-page angles for layout review — payload bay, clearances, and gear height.
Isometric
Overall layout: payload bay, landing gear, companion mount.
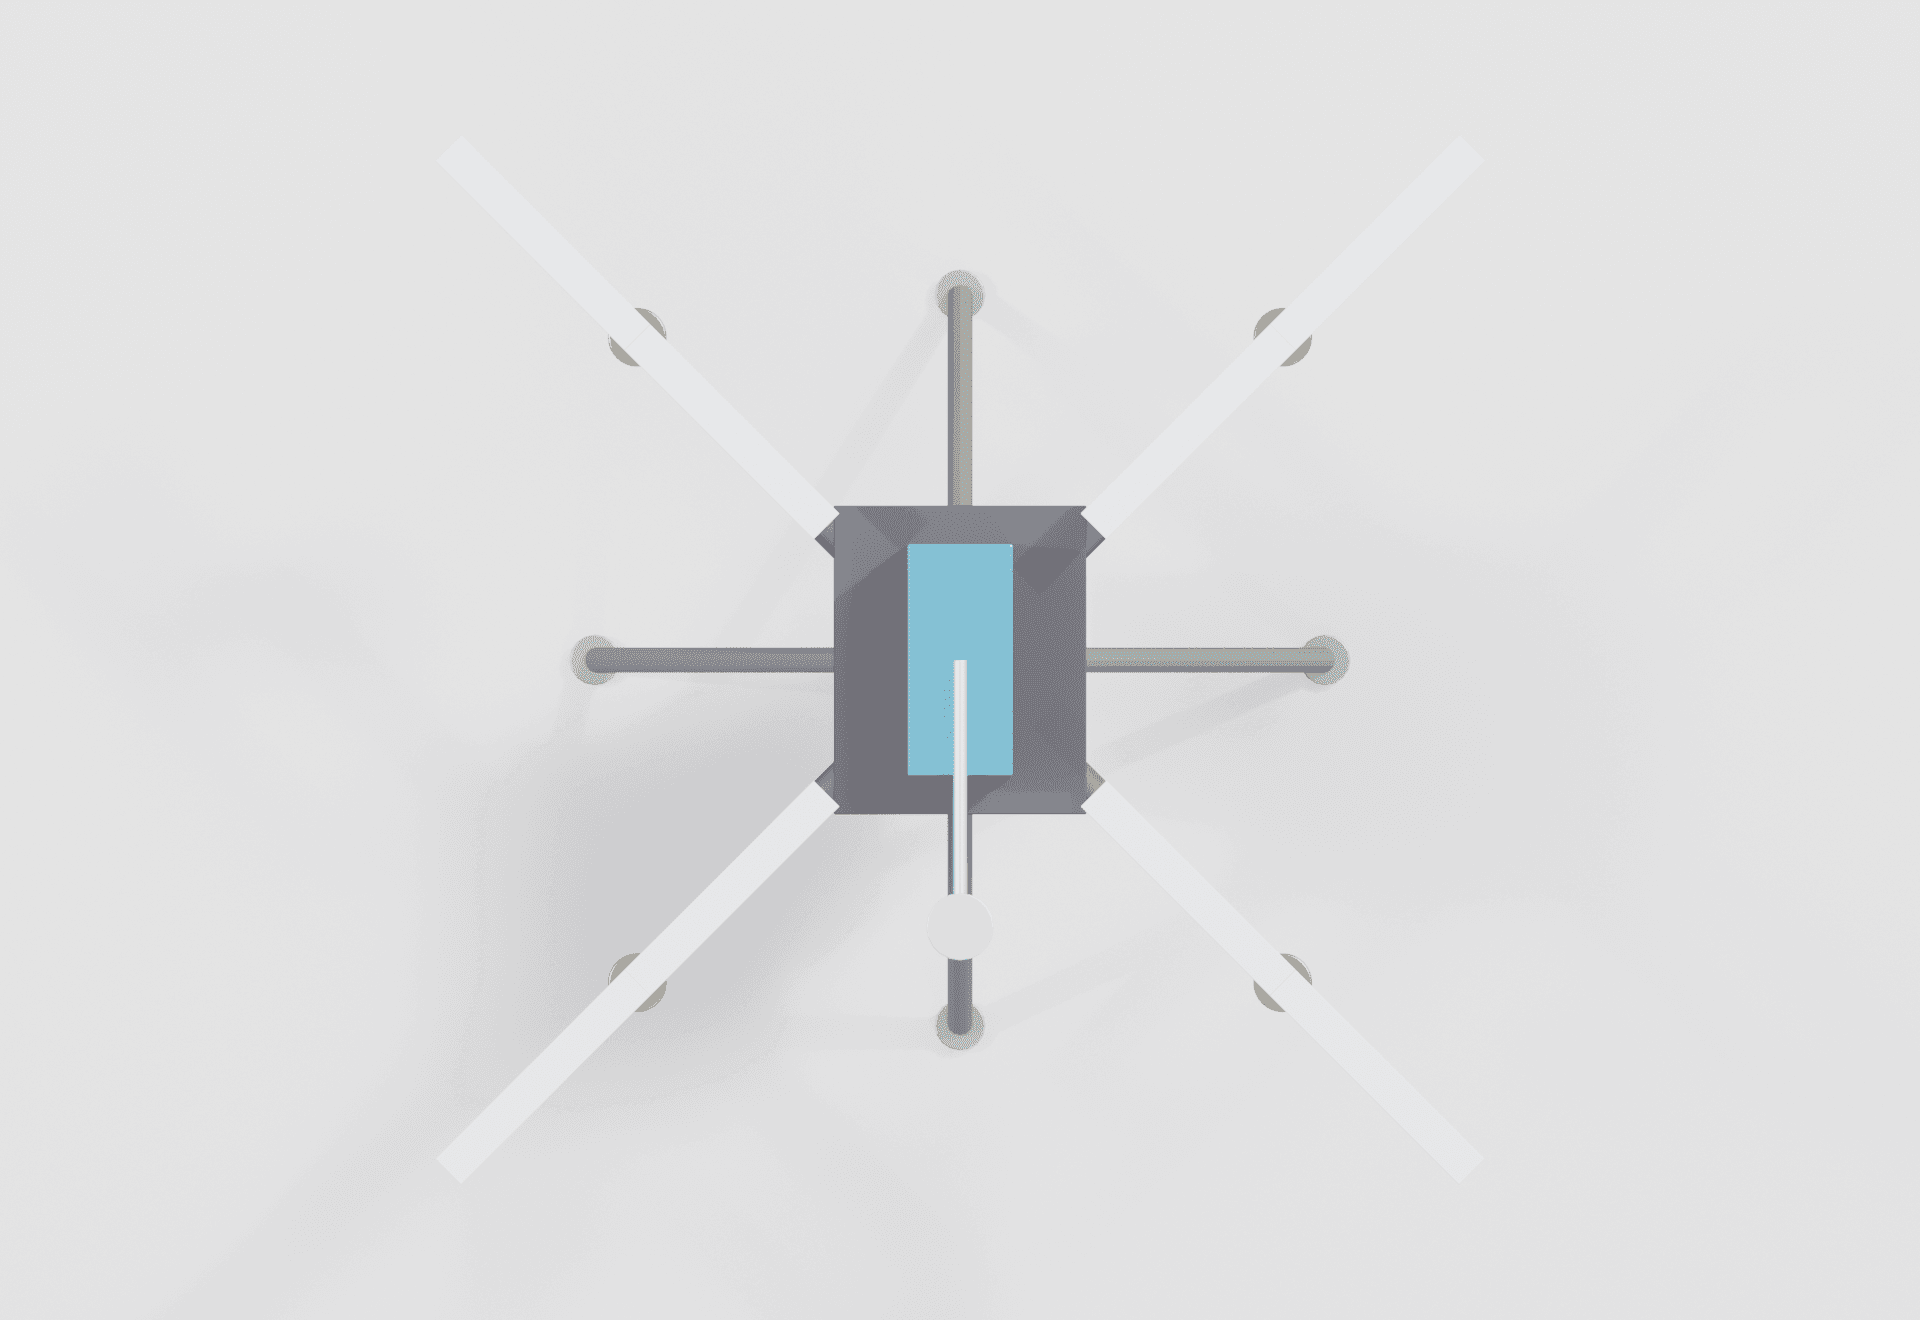
Top
Plan view for bay and antenna / radio clearances.
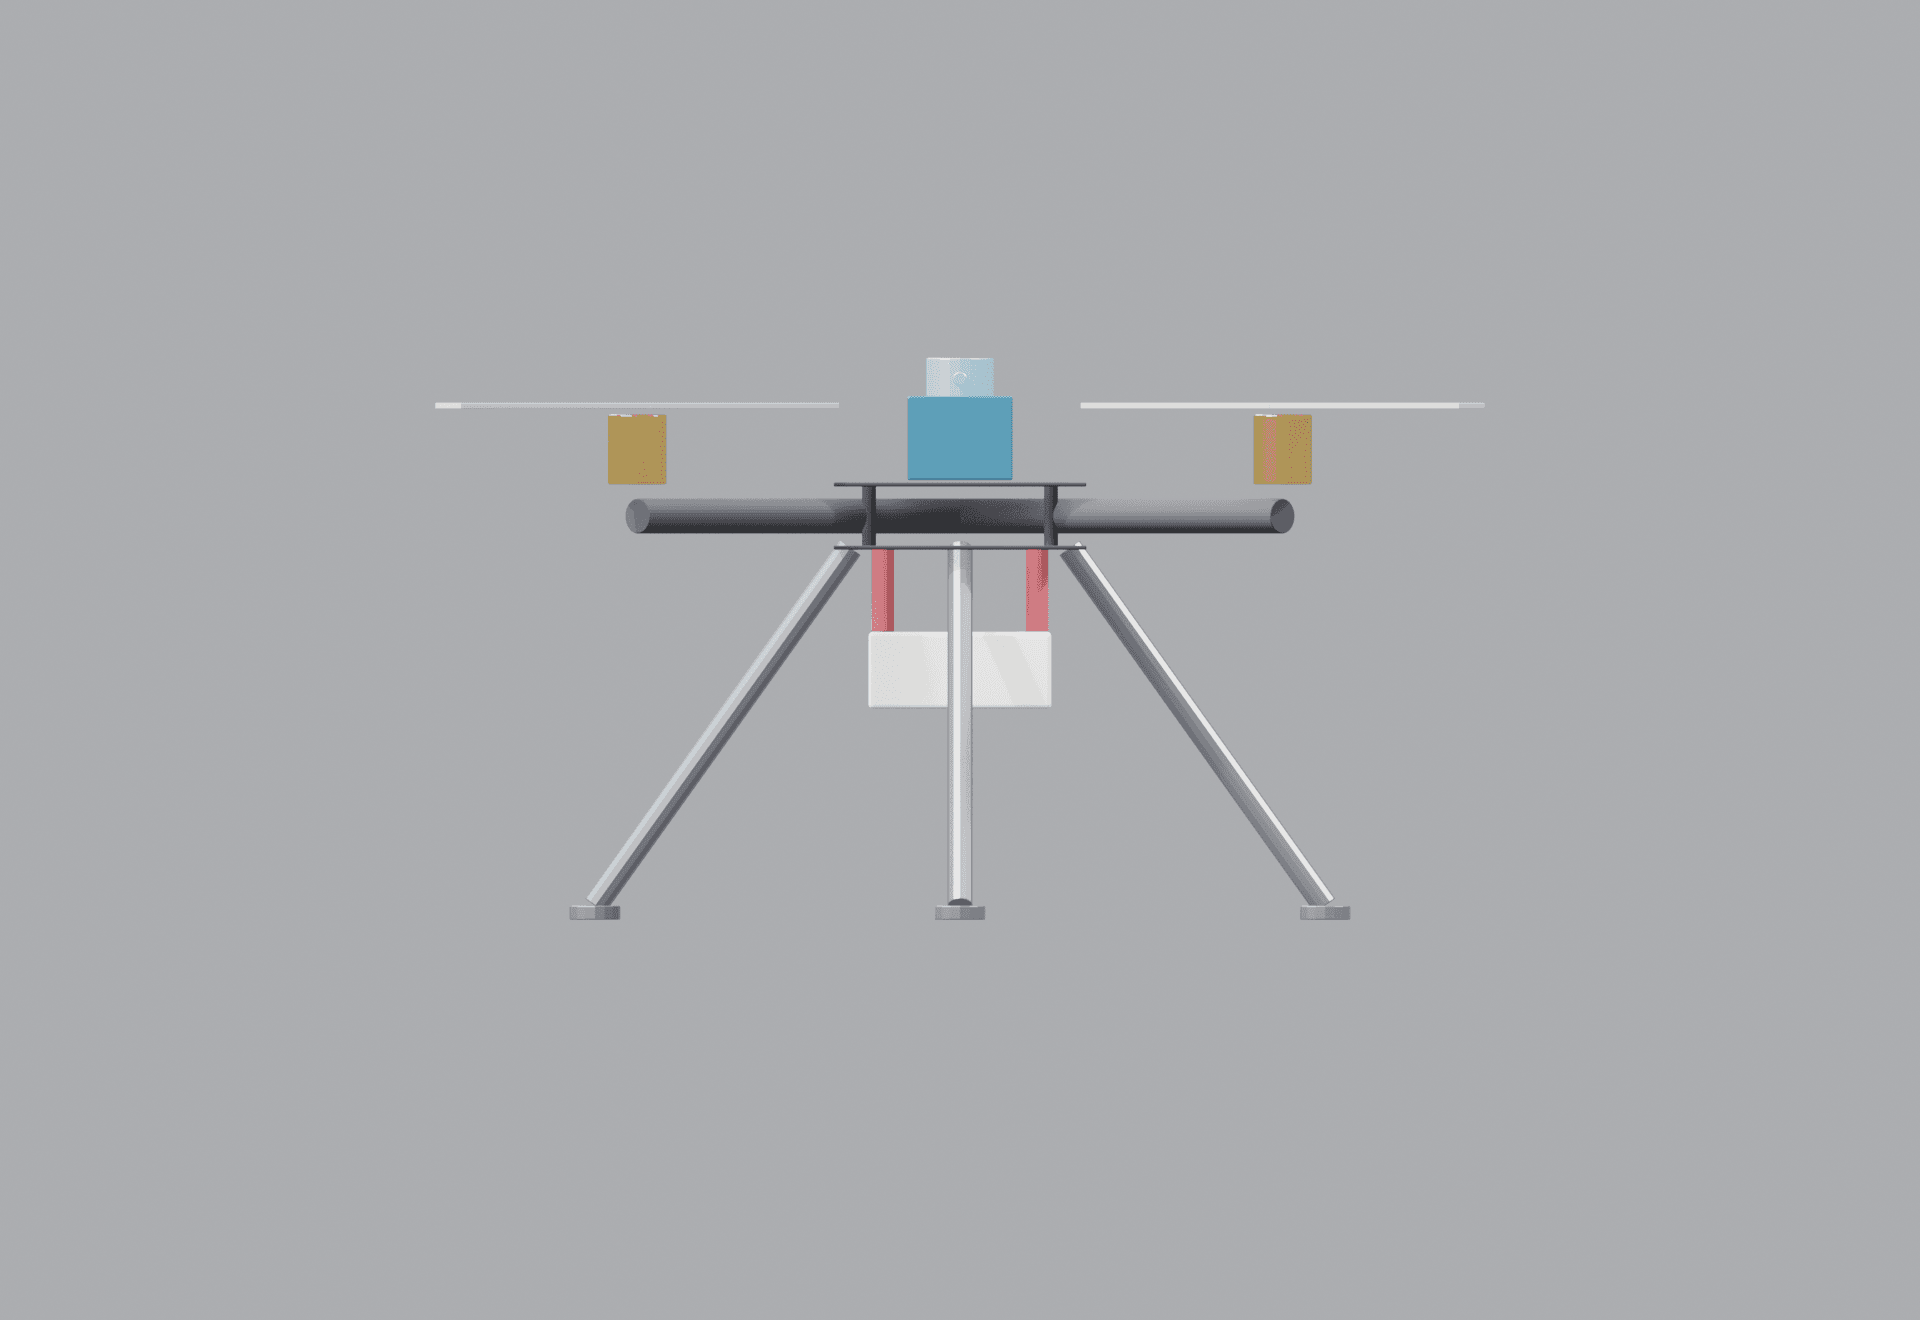
Side
Belly camera height and gear clearance for rough fields.
Stack
| Role | Hardware | Owns |
|---|---|---|
| Flight | Pixhawk / Cube | Attitude, nav, failsafes — survives Pi death |
| Companion | Pi 5 8 GB + AI HAT+ 26 TOPS | Capture, QA, inference, indices, spool (read-only MAVLink) |
| Camera | Camera Module 3 (IMX708) | Default sensor for georeference model; verify channel order |
| Positioning | RTK GNSS (+ NTRIP) | Corrections → receiver serial, not FC MAVLink |
Staged spend (approx. CAD)
- Stage 0FreeWSL2, Docker, GPU power mode — unblocks SITL, Hailo compile, WebODM, farmOS
- Stage 1~C$400Pi 5, cooler, PSU, SD, Camera Module 3, reflectance panel — local imagery without an aircraft
- Stage 2~C$150AI HAT+ 26 TOPS — tiled weed survey becomes flyable (~288 ms vs seconds on CPU)
- Stage 3C$1,200–2,500Airframe, FC, batteries, RC, telemetry, rangefinder for AGL
- Stage 4–5C$750–1,950RTK / NTRIP, anemometer on a field-edge mast (not airframe downwash)
Livestock demo first if budget is tight: aerial_sheep_yolox_s (AP@.50 0.905) runs on a bare Pi. See pipeline proof.